Unity Robotics Sim & VLA Teleoperation
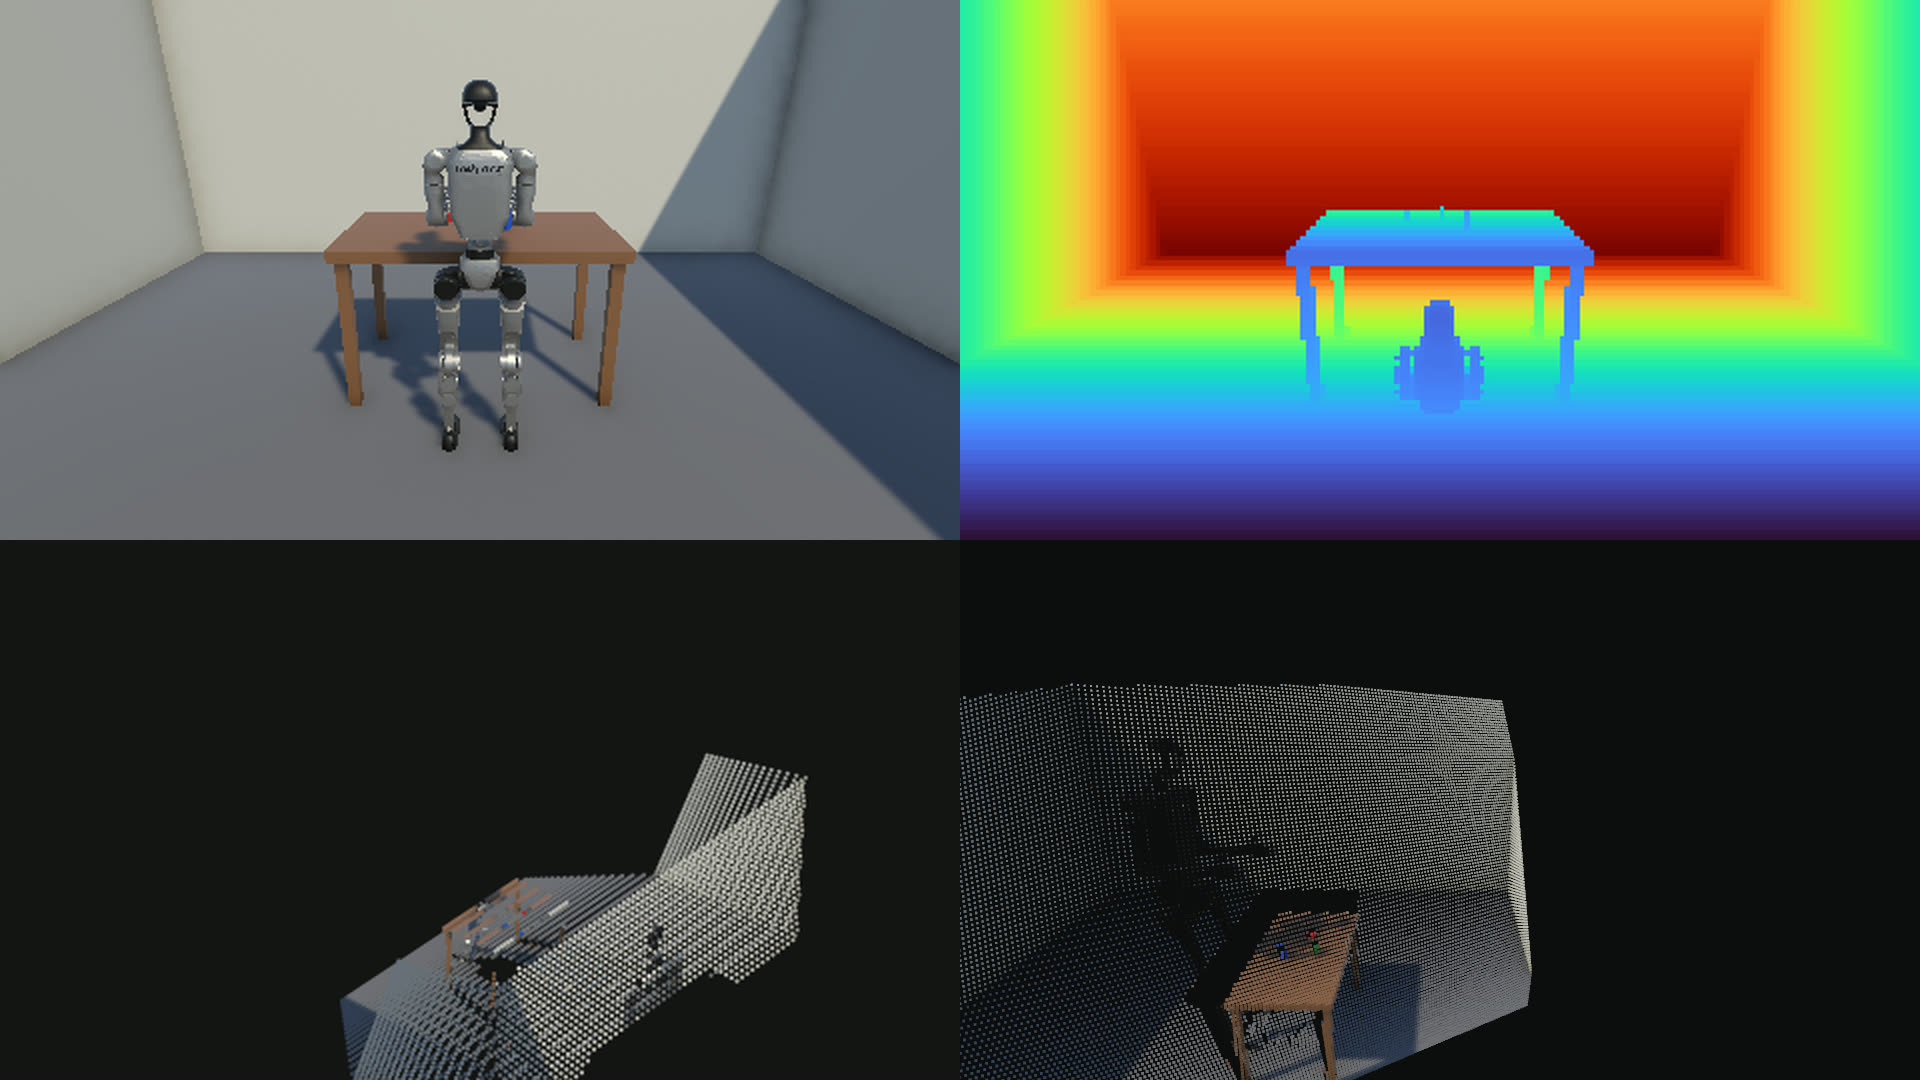
A Unity robotics simulation loop: a simulated Unitree G1 driven by NVIDIA GR00T N1.7 served from our DGX Spark, plus Meta Quest 3 teleoperation and VR point clouds.
We built a Unity simulation loop in which a simulated Unitree G1 is driven by NVIDIA GR00T N1.7, a vision-language-action model served from our DGX Spark. We recorded scripted demonstrations in Unity, fine-tuned GR00T on the Spark, and served the fine-tuned policy back into the same sim — early-stage results, but the record, fine-tune and serve loop closes. Alongside it, QuestTeleop turns a Meta Quest 3 into a hand- and head-tracking controller for simulated humanoids and Reachy Mini, and simulated depth streams into a VR point cloud. It's all documented in a 20-chapter workbook, Teaching a Robot to Take Instructions.